FANUC Series 30i/31i-MODEL A Specifications for Speed Command Extension in Least Input Increments D and E Additional Manual Page 4
Additional Manual
A-79510E
Title
Draw
No.
Ed. Date Design Description
Date Sep.10.’04 Design. Apprv.
4/6
page
FANUC Series 30i/31i-MODEL A
Specifications for Speed Command Extension
in Least Input Increments D and E
Restrictions
- Parameters of time constants for linear acceleration/deceleration after interpolation and
bell-shaped acceleration/deceleration after interpolation
When linear acceleration/deceleration after interpolation or bell-shaped
acceleration/deceleration after interpolation is used in rapid traverse, cutting
feed or manual feed, the maximum specifiable time constant is half of the
former maximum specifiable value.
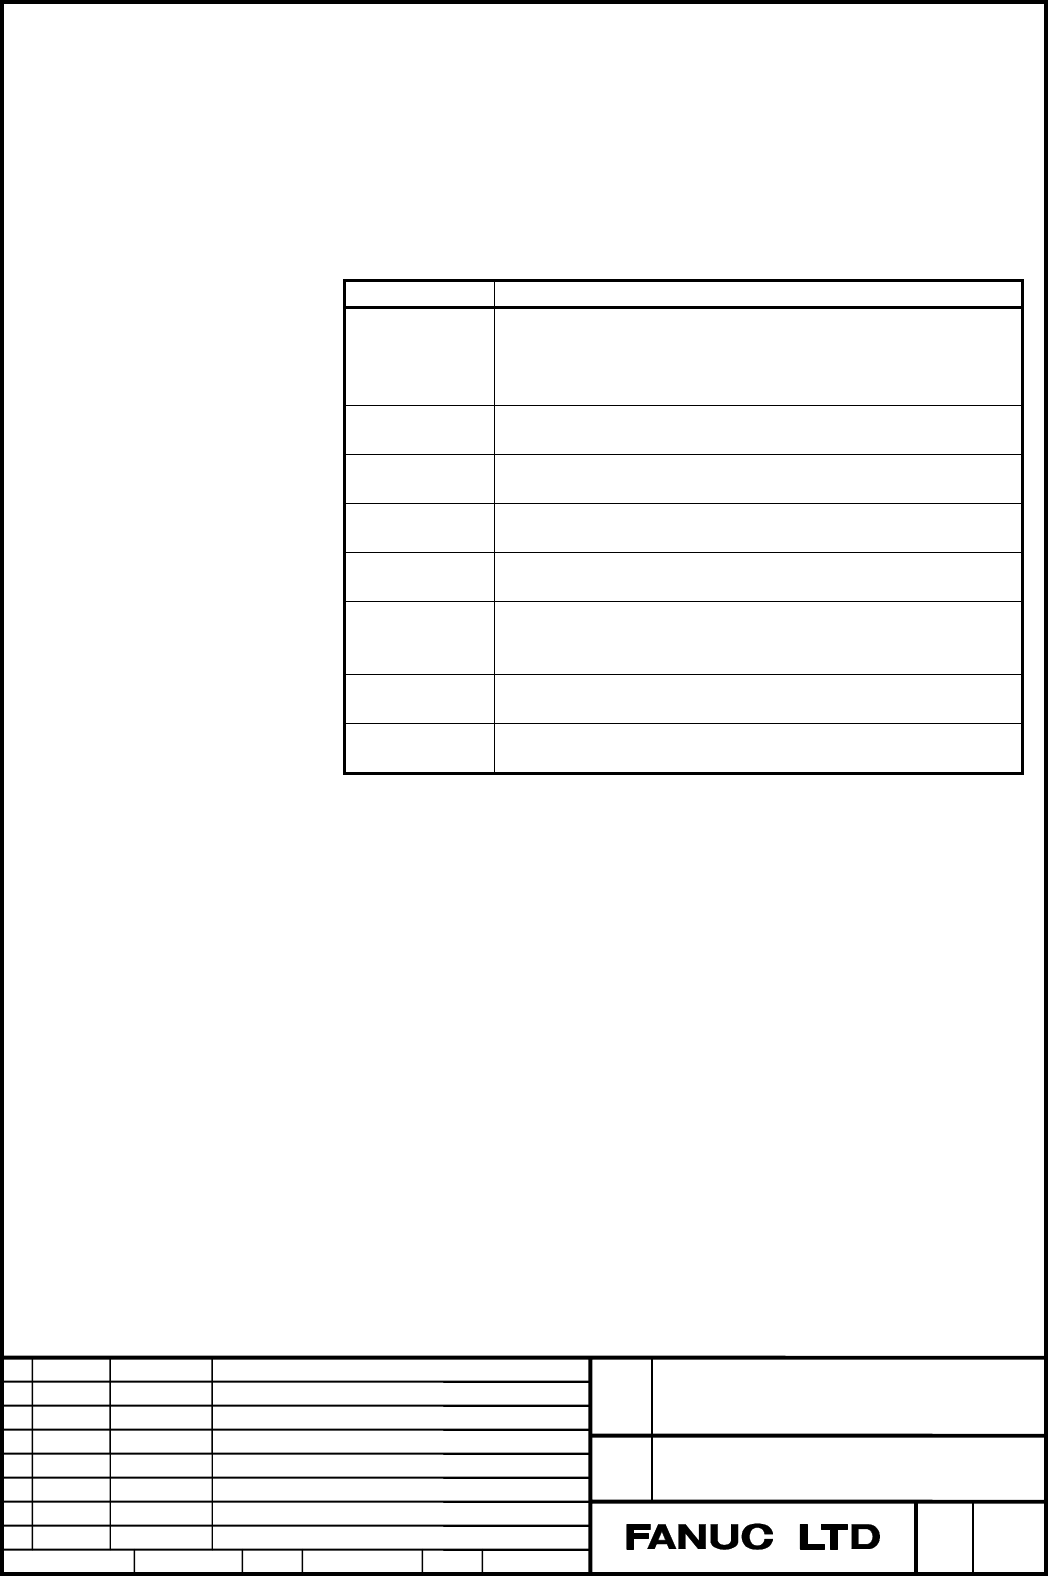
The table below indicates the parameters for related time constants.
Parameter No. Meaning of parameter
1620 Time constant (T) for rapid traverse linear
acceleration/deceleration for each axis, or time constant (T1)
for rapid traverse bell-shaped acceleration/deceleration for
each axis
1621 Time constant (T2) for rapid traverse bell-shaped
acceleration/deceleration for each axis
1622 Time constant for cutting feed acceleration/deceleration for
each axis
1624 Time constant for manual continuous feed
acceleration/deceleration for each axis
1626 Time constant for acceleration/deceleration in a threading cycle
for each axis
1769 Time constant for cutting feed acceleration/deceleration after
interpolation in the acceleration/deceleration before
interpolation mode
5271-5274 Time constant for acceleration/deceleration for extraction in
rigid tapping (the first gear to the fourth gear)
5365-5368 Time constant for bell-shaped acceleration/deceleration in rigid
tapping (the first gear to the fourth gear)
- VCMD waveform display function
As speed increases, the value of data that can be obtained with VCMD
waveform display increases. So if the value exceeds the permitted range,
an incorrect waveform may be displayed.
- Positional deviation display on the servo adjustment screen
If the positional deviation exceeds -9999999 when a high-speed movement
is made in the minus direction, the displayed number of digits is decreased
by one from the correct number of digits because of space available for
display.
To check the correct positional deviation, see No. 300, "Servo Positional
Deviation", on the diagnosis screen.
Contents Summary of FANUC Series 30i/31i-MODEL A Specifications for Speed Command Extension in Least Input Increments D and E Additional Manual
- Page 1FANUC Series 30i/31i-MODEL A Specifications for Speed Command Extension in Least Input Increments D and E FANUC Series 30i/31i-MODEL A Title Specifications for Speed Command Extension in Least Input Increments D and E Draw A-79510E No. Ed. Date Design Description page 1/6 Date Sep.10.’04 Design. App
- Page 2Overview When the least input increment D (IS-D) or E (IS-E) is selected, up to now the limitations indicated in Table 1 and Table 2 are imposed on parameters for speed and acceleration/deceleration. This means that when the unit of data is mm, and the increment system is IS-E, for example, no rapid
- Page 3- Parameters for speed and angular velocity when this function is used Increment Least data Unit of data Valid data range system increment mm/min IS-D 0.0001 0.0000 to +99999.9999 deg /min IS-E 0.0001 0.0000 to +99999.9999 IS-D 0.00001 0.00000 to +4000.00000 inch/min IS-E 0.00001 0.00000 to +4000.00
- Page 4Restrictions - Parameters of time constants for linear acceleration/deceleration after interpolation and bell-shaped acceleration/deceleration after interpolation When linear acceleration/deceleration after interpolation or bell-shaped acceleration/deceleration after interpolation is used in rapid t
- Page 5Parameter #7 #6 #5 #4 #3 #2 #1 #0 1013 IESP [Input type] Parameter input [Data type] Bit axis #7 IESP When the least input increment is D(IS-D) or E(IS-E), the function to allow to set the larger value to the parameter of the speed and the acceleration: 0: Not used. 1: Used. As for the axis which se
- Page 6#7 #6 #5 #4 #3 #2 #1 #0 2282 ISE64 [Input type] Parameter input [Data type] Bit axis #3 ISE64 The speed limitation of feed forward(Parameter No.2005#1(FEED)=1): 0: Former specification. 1: Extended specification. The feedrate limitation is shown in the following tables, when the feed forward functio