Spindle Motor (Synchronous Motor) Mounting sensor & Starting sequence Specifications Additional Manual Page 6
Additional Manual
Rev
DATE
CONTENTS
Takahashi
Design
TITLE
DNr. A-63639-067E
FANUC
PAGE
6/8
02
2000.11.09
PRM4008#6 added Toyozawa
Synchronous Spindle Motor
Mounting Sensor/Starting sequence
Specification
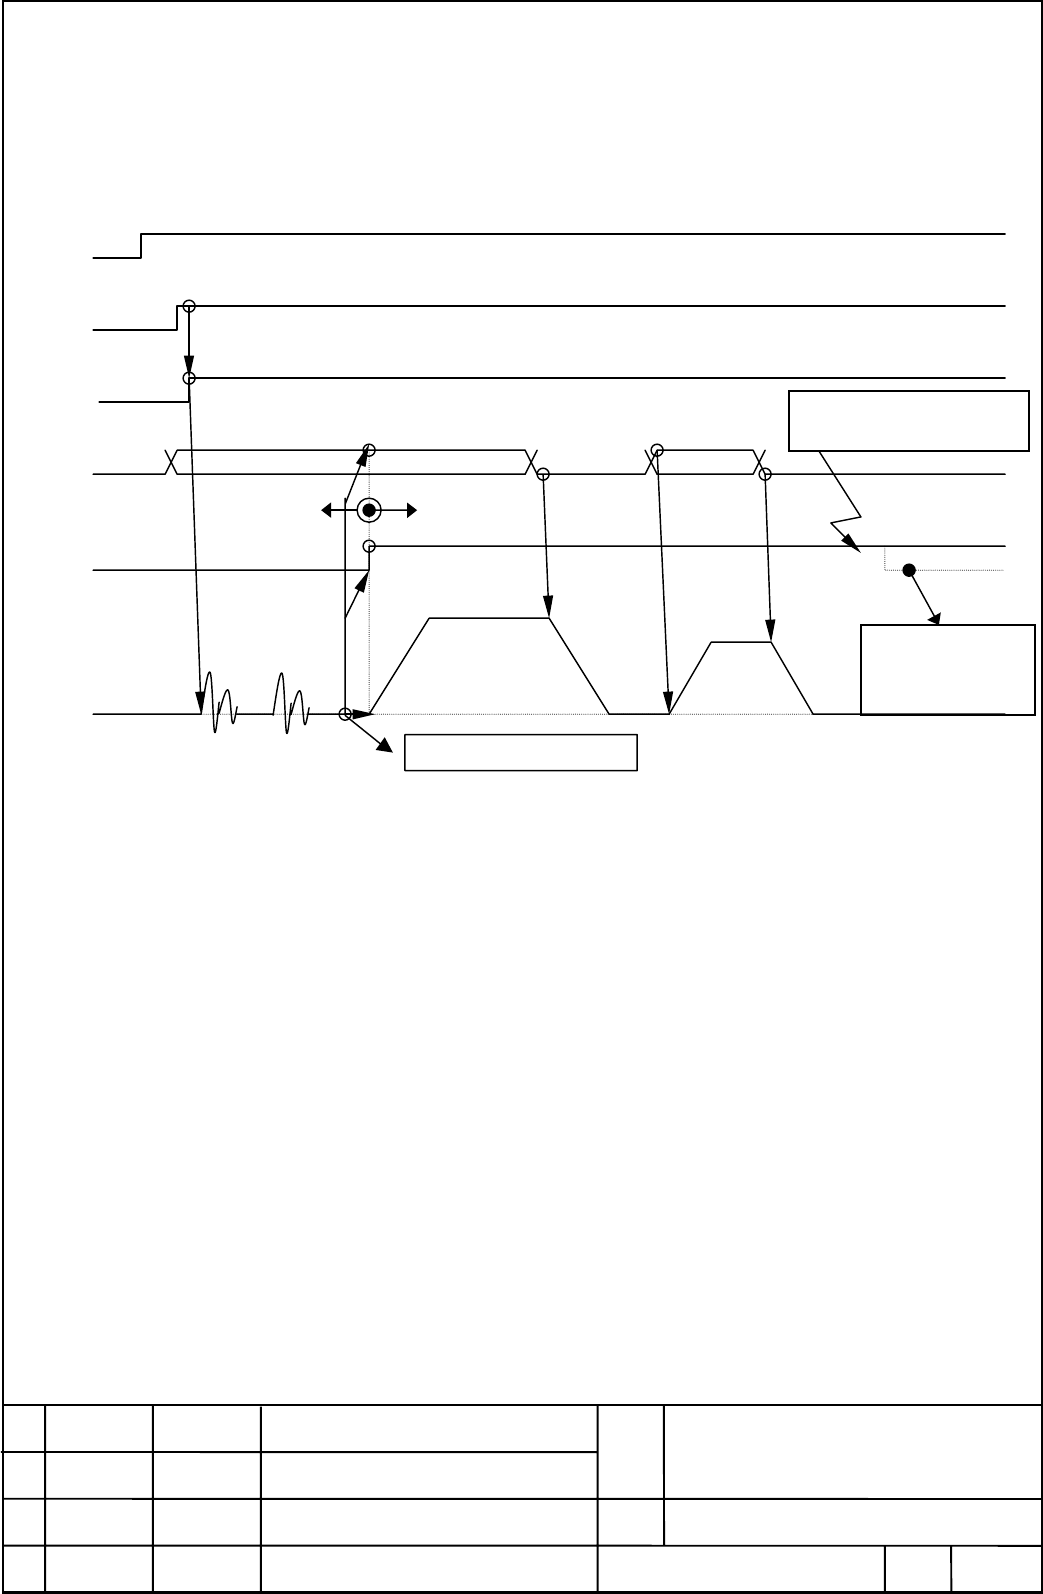
2.1.The sequence of Pole position detection
2.1.The sequence of Pole position detection2.1.The sequence of Pole position detection
2.1.The sequence of Pole position detection
The pole detection works only once after Power on or after happening of alarm that lose the pole position.
The sequence of it is as (1) and (2) as described below.
2.1.1.SFR/SRV is trigger signal case
2.1.1.SFR/SRV is trigger signal case2.1.1.SFR/SRV is trigger signal case
2.1.1.SFR/SRV is trigger signal case
When SFR/SRV is input in the lost pole position (EPFIX=0), that invokes automatically the pole
detection sequence in advance of executing the velocity command. Then after it is done with EPFIX=1
showing the pole setting, the velocity command get valid to run the motor.
(1) Get the motor ready to drive by the velocity command after Power ON.
(2) Set either SFR or SRV exclusive to 1.
(3) Pole detection starts automatically in case of the lost pole state,EPFIX=0.
(4) Pole detection sets the temporary pole position after moving at 0 position then at 90 position
(5) Temporary pole position setting outputs EPFIX=1 and the validated velocity command drive the
motor. Afterward it is usual velocity mode.
(6) If an alarm happens which could lose the pole position already acquired, that makes EPFIX=0 of
the lost pole position. Next velocity command tries again the pole detection sequence.
Power
MRDY
& *ESP
SFR or
SRV
Velocity
command
EPFIX
Motor Velocit
y
0 position 90 position
movin
g
movin
g
Pole set
V
alid velocit
y
command
Lost pole position
Invalid velocit
y
command
Lost pole pos.
Invalid velocity
command
A
larm lost pole position
ha
pp
ens
、
EPFIX=0
P
o
l
e
detect
i
o
n
co
m
p
l
ete
Contents Summary of Spindle Motor (Synchronous Motor) Mounting sensor & Starting sequence Specifications Additional Manual
- Page 1Spindle Motor (Synchronous Motor) Mounting sensor & Starting sequence Specifications 1. Mounting sensor............................................................................................................................2 1.1 BZ sensor .........................................................
- Page 21. Mounting sensor The current of the synchronous motor is controlled according to the pole position of the magnet built in the motor rotor. There are two method prepared in the spindle control software in order to get the pole position. The first method uses a reference signal of BZ sensor as zero
- Page 3running out of the center moving of the ring within ±0.03mm for the detector. (7) Turn off DC supply and make certain the feedback signal correctly output. Refer to “FANUC BUILT-IN AC SPINDLE MOTOR α series specification description B-65202” as to the way of confirmation. (8) After moving the shaft
- Page 42. Starting sequence It is necessary that Spindle software recognizes the pole position of the synchronous motor to control the current. Spindle software uses BZ sensor with the synchronous motor to recognize the pole position. From now on, we abbreviate “the spindle software in Spindle module” to S
- Page 5rotation depends on initial position at the time. •Alarm 65 is issued when the rotation angle from 0 to 90 degrees position amount less than 80 degrees after confirming the stall at 90 degrees position. This might happen if the motor is locked up mechanically. If so, release it to move the motor aft
- Page 62.1.The sequence of Pole position detection The pole detection works only once after Power on or after happening of alarm that lose the pole position. The sequence of it is as (1) and (2) as described below. 2.1.1.SFR/SRV is trigger signal case Power MRDY & *ESP SFR or SRV Alarm lost pole position h
- Page 72.1.2. EPFSTR is the trigger signal case Power MRDY & *ESP Alarm lost pole position & SFR/SRV happens、EPFIX=0 EPFSTR Velocity command Lost pole position Pole set Invalid velocity command Valid velocity command EPFIX Lost pole pos. Invalid velocity command Motor Velocity 0 position 90 position Pole d
- Page 82.2.PMC signal for Pole position detection The below table summarizes the PMC signal necessary to achieve pole detection. The bold type is added this time for the synchronous motor. INPUT (PMC → CNC) FS15 FS16 #7 #6 #5 #4 #3 #2 #1 #0 G227 G070 MRDY SFR SRV G226 G071 *ESP G228 G073 EPFSTR SYMBOL MEAN